|
Addy (Jin Hyun) Park I am a researcher at the AI & Robotics Institute, Korea Institute of Science and Technology (KIST). Previously, I spent a year as a research engineer at the Autonomous Systems Lab at Cornell University, where I worked on safe motion planning under observation uncertainty. I also completed my undergraduate and master's degrees in mechanical engineering at Cornell. |
|
ResearchMy research interests lie in safe motion planning and control of autonomous systems under uncertainty. I am particularly interested in optimization-based and sampling-based model predictive control, uncertainty-aware planning with safety guarantees, and trajectory optimization, with applications to mobile robots, manipulators, humanoids, and aerospace vehicles. |
|
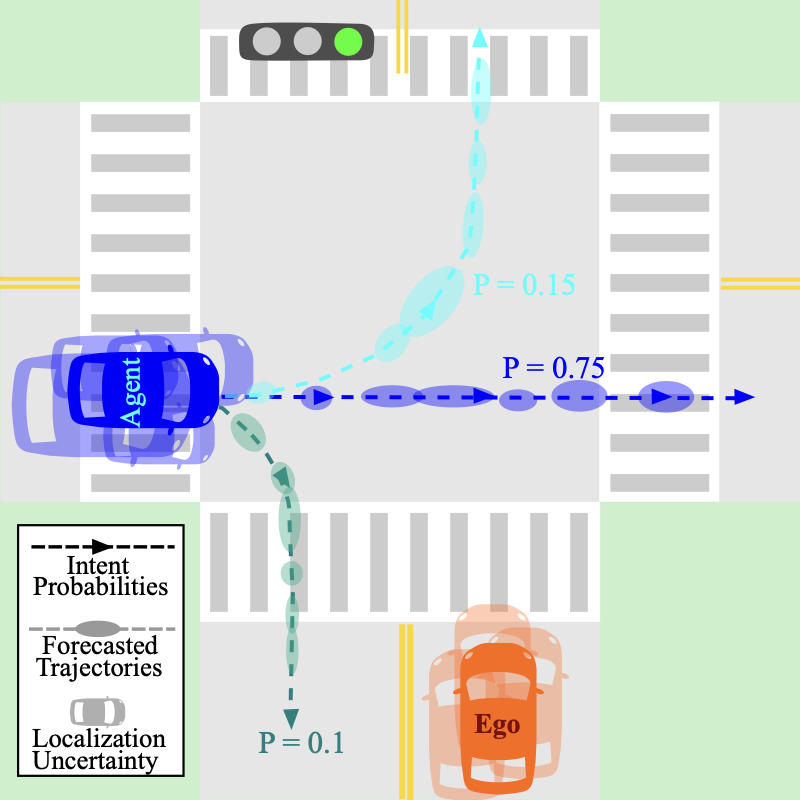
Interpretable Collision Avoidance and Feasibility Guarantees through an Uncertainty Aware Pipeline
Doris Xu, Jin Hyun Park, Guadalupe Alvarado Fernandez, Adhyan Prasad, Mark Campbell IEEE IROS, 2026 arXiv A modular perception-prediction-planning pipeline that propagates interpretable uncertainty across module boundaries, guaranteeing both probabilistic collision avoidance and real-time solver feasibility for autonomous navigation. |
|
Website template from Jon Barron. |